RoboGesture Makes a G1 Talk With Its Hands
A Unitree G1 with BrainCo hands that flashes an OK sign when it says “OK,” and pats its chest on “seize the chance,” is the demo. RoboGesture, from Galbot, Tsinghua, Peking University, and partners, is the stack. The paper is arXiv:2608.28693, accepted at ECCV 2026 (poster session 2, 10 September, ExHall 178). Galbot posted the launch on 5 September.
The robot does not retarget a human skeleton at runtime. It generates motion in its own 41-DoF upper body: 17 torso and arm joints, 24 on the two hands.
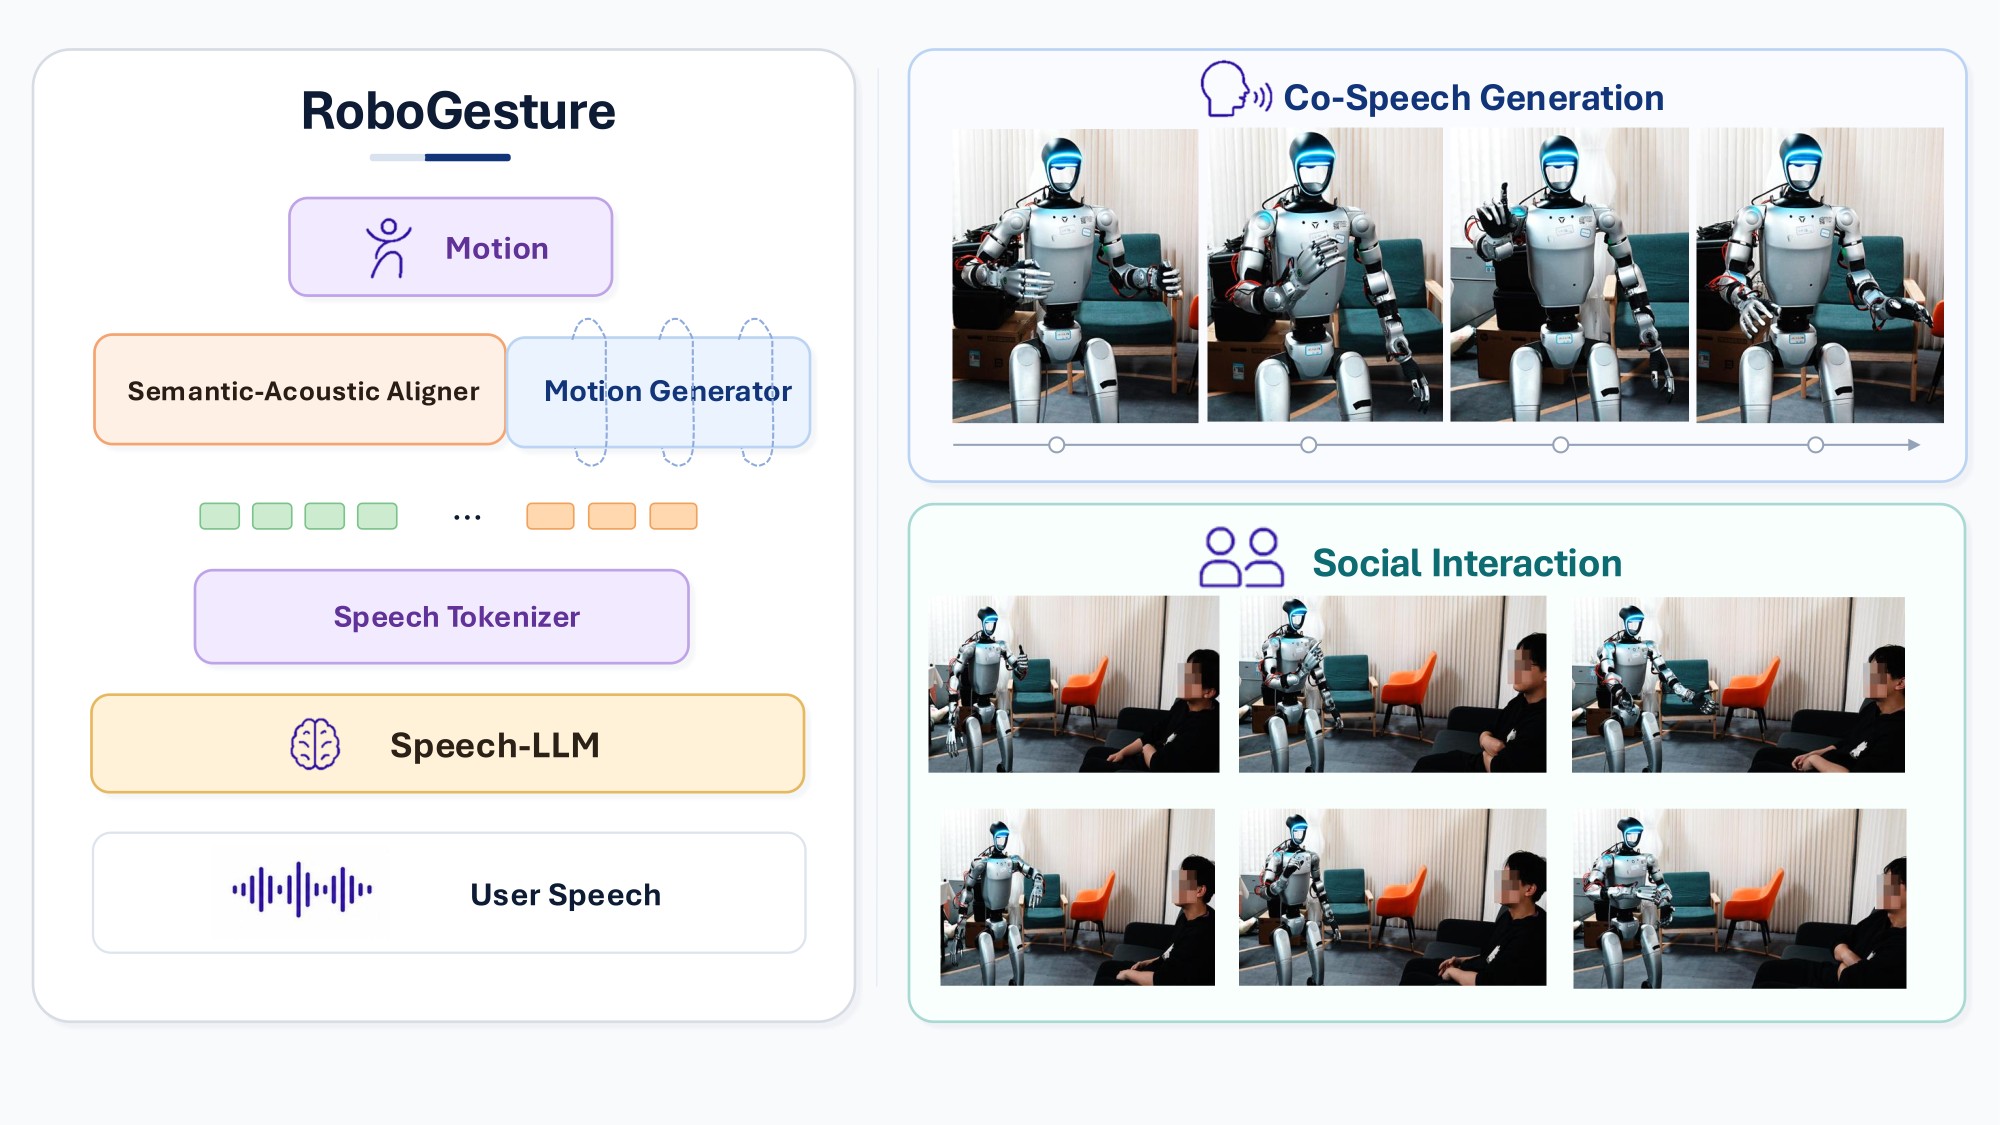
Listen, then move
Streaming audio is tokenized with the Mimi codec. A hierarchical aligner splits the job: shallow layers watch beats, deep layers classify among 300+ gesture categories. A diffusion transformer with conditional flow matching then writes the next motion chunk. The team calls the failure mode modality eclipse: the model keeps waving because last frame said wave, not because the speech still wants it. Anti-Inertia CFG masking drops historical motion 15% of the time in training so the audio has to drive the pose.
Semantic gestures are timed to start 0.4 s before the spoken keyword. An MPC safety filter, 5.6 ms per frame, is a convex QP with collision constraints. The project page says it sits comfortably above a 30 Hz control loop. On the BEAT set, self-collision frames drop from 4.16% to 0.13% with the filter; the paper’s BEAT collision rate for the full model is 0.88%, 0.13% on SemanticBEAT.
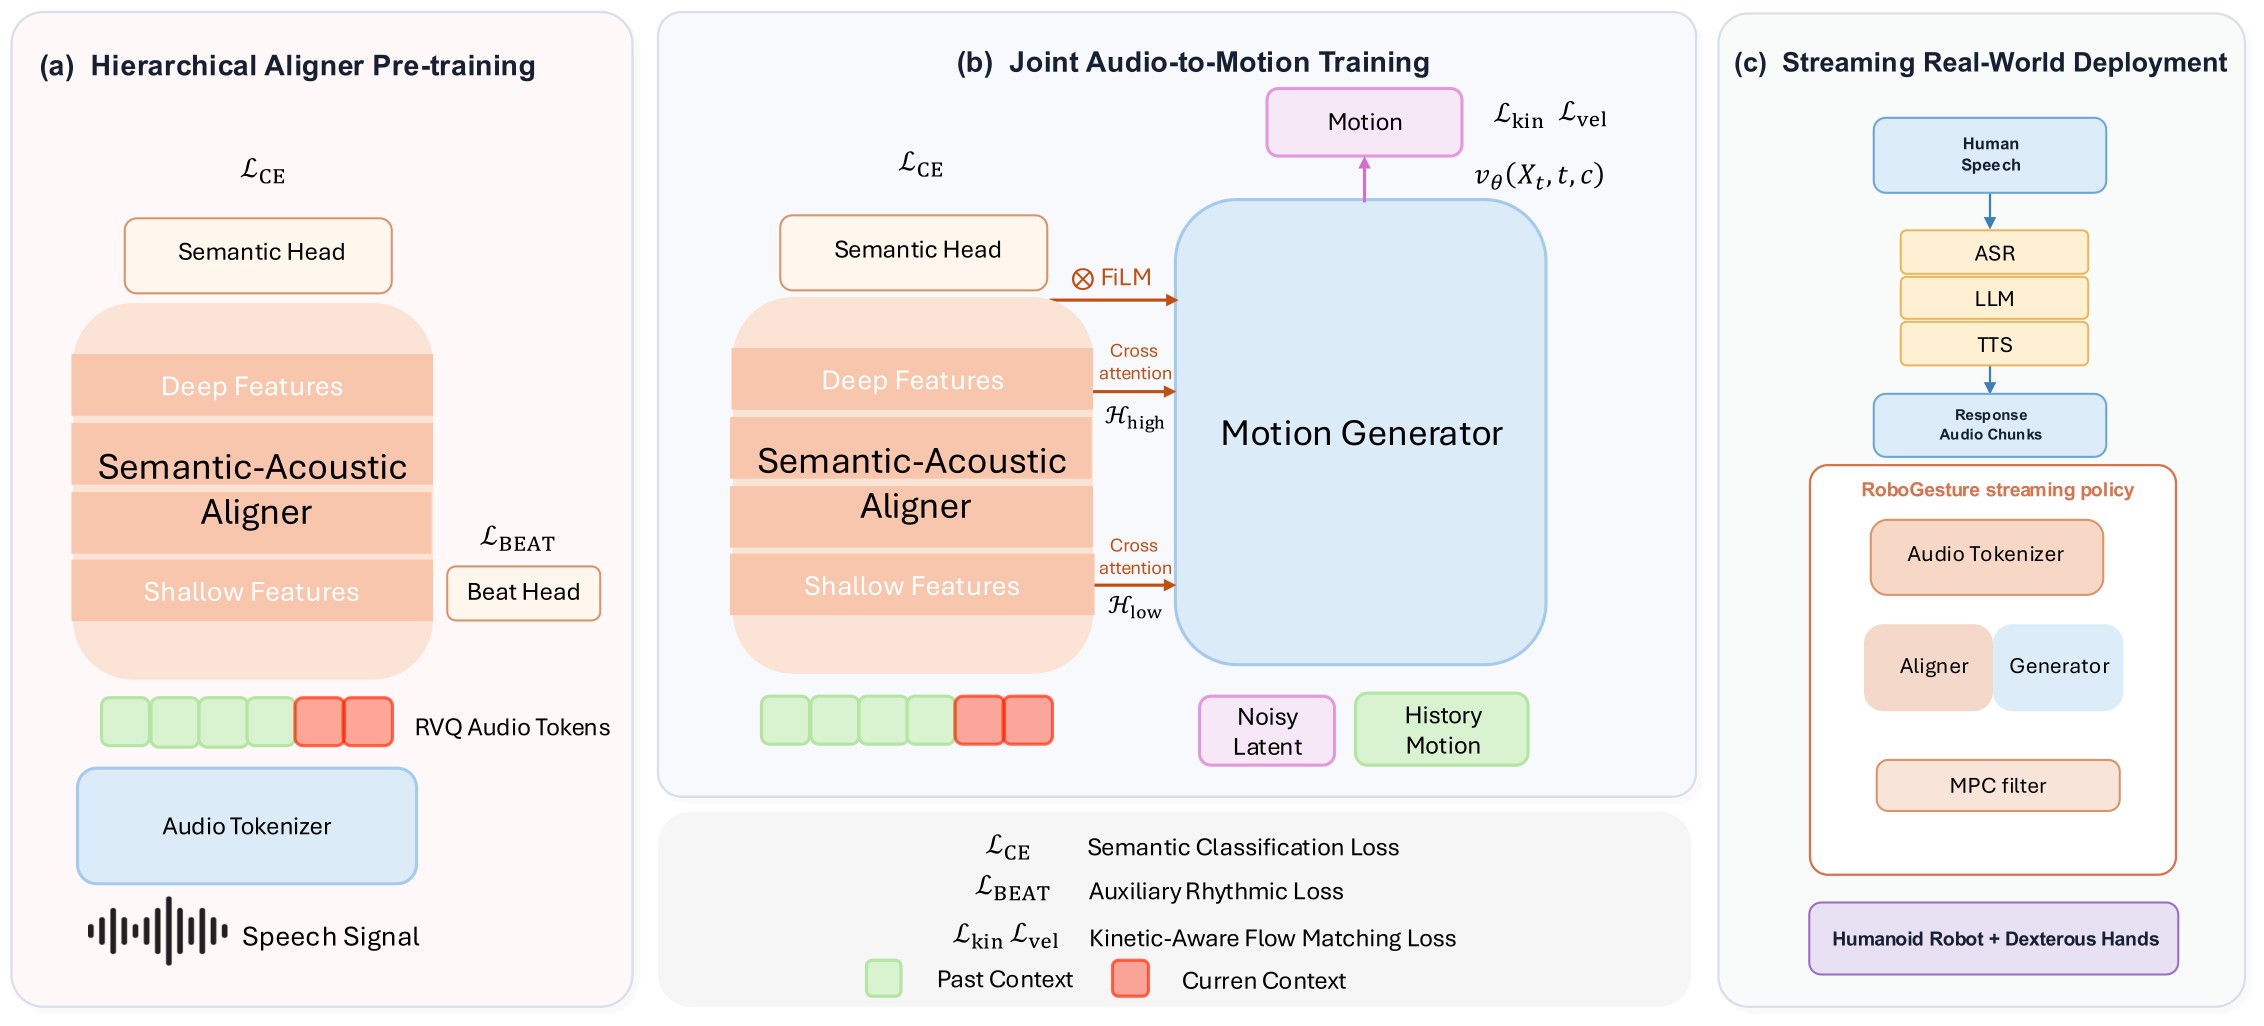
Motion generation itself is about 120 FPS. Galbot’s advertised listen → respond → gesture loop is roughly 2 seconds. Humanoids Daily, citing the paper’s per-module split, puts the bulk of that wait on ASR, a LoRA-tuned LLM, and TTS, not on the gesture net.
Dataset and scores
The RoboGesture set has 300+ mocap categories, then a semi-synthetic pipeline that builds 1,000 hours of robot-specific audio-motion pairs. On BEAT, Fréchet Gesture Distance is 0.8452 versus 2.2316 for DiffSHEG and 3.0147 for Semantic Gesticulator. Beat consistency is 0.1866. Humanoids Daily reports 200 real G1 trials with zero falls and zero emergency stops. Lower-body balance stays with the G1’s standing controller. The current policy is stationary upper body, not walking-and-talking.
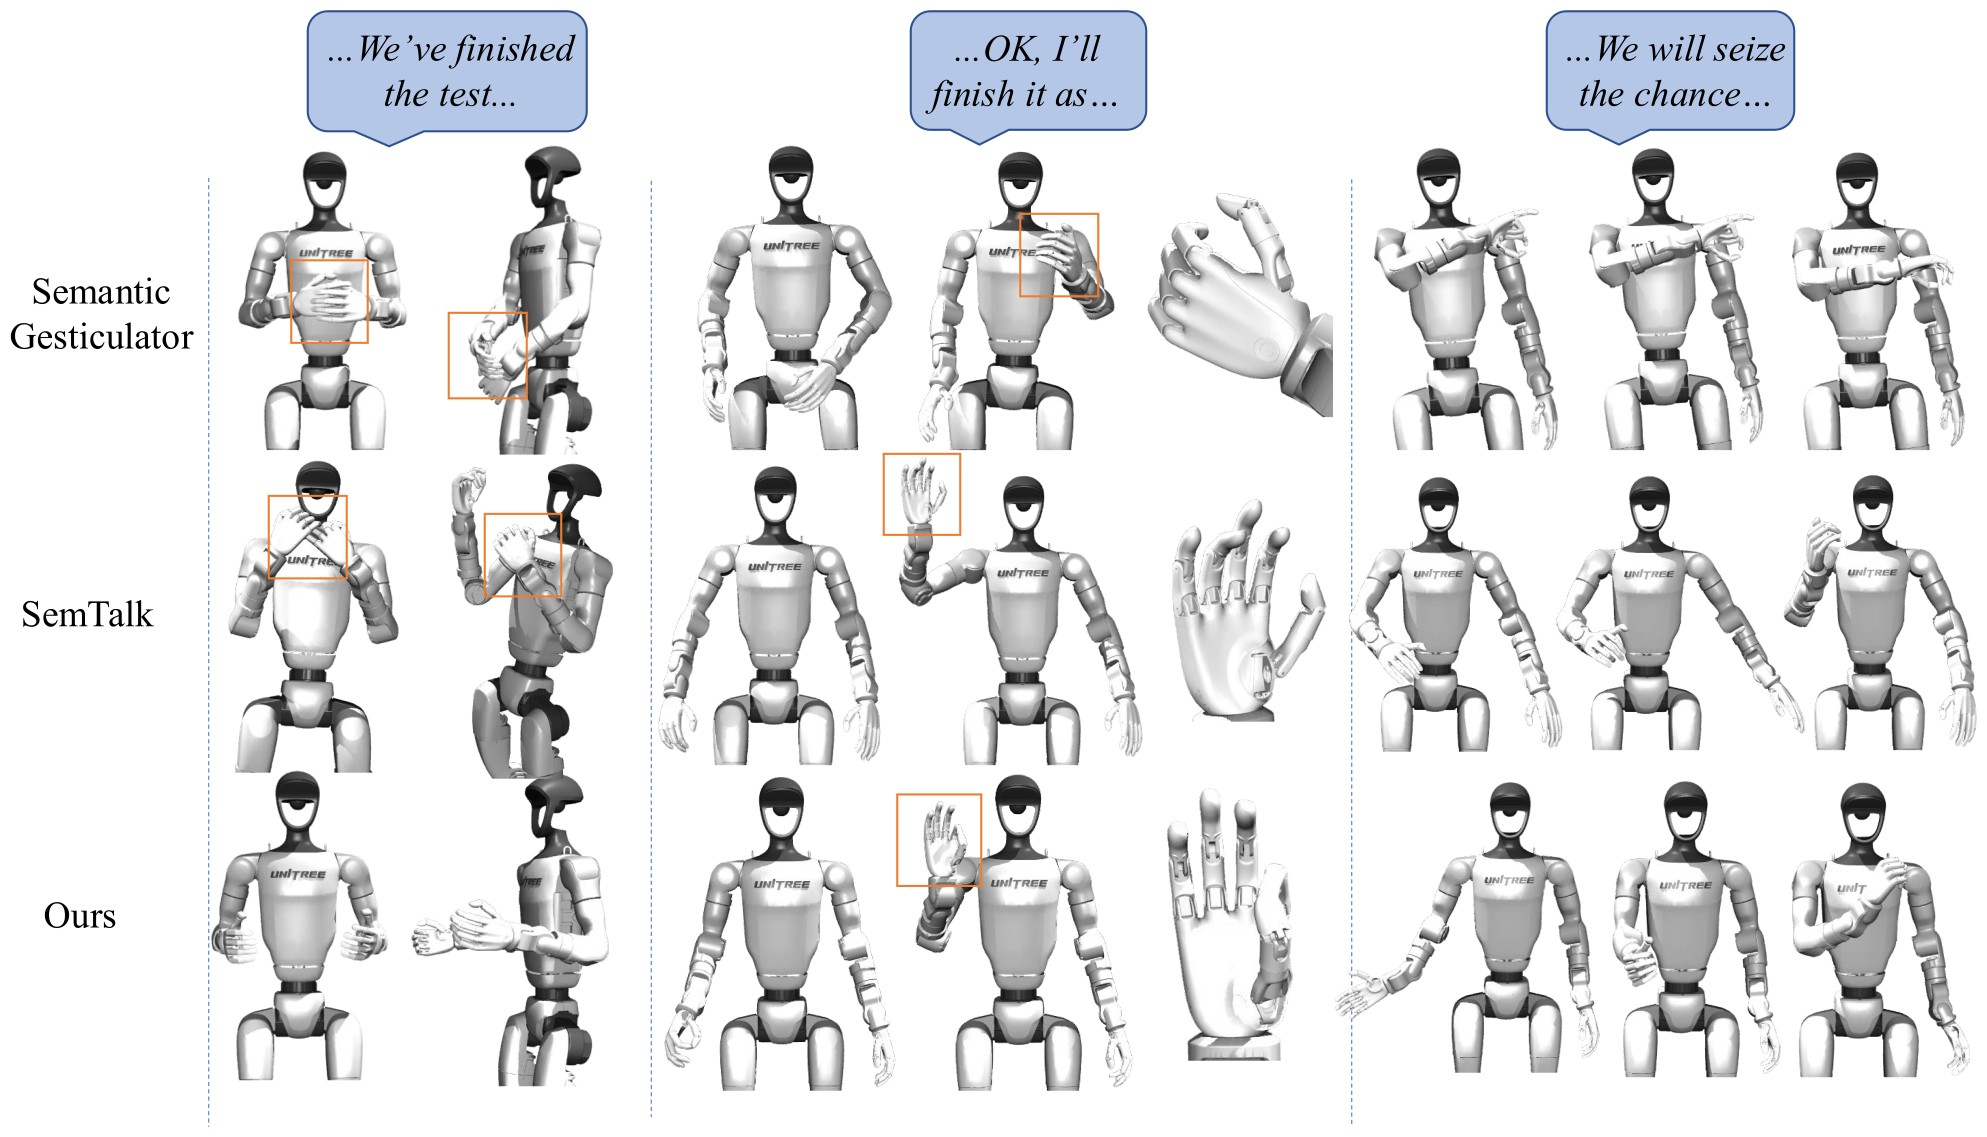
A Human’s Take
I like that they generate in robot joint space instead of hoping IK will forgive a human shrug. The 2-second loop is still a stage pause, not a hallway chat. If the MPC keeps hands off the chest at 5.6 ms, that is the part I would actually ship.