IMLE-VLA Drops the 10-Step Action Head and Hits 55 Hz
A lot of VLA lag is not the GPU. It is the 10 Euler steps inside the action head. IMLE-VLA, accepted at IROS 2026, deletes that loop.
Researchers at Simon Fraser University and the University of Pennsylvania keep π0.5’s frozen VLM and swap the flow-matching expert for a single-step generator trained with conditional Implicit Maximum Likelihood Estimation. On an NVIDIA L40S, inference goes from 15 Hz to 55 Hz (3.67×). The paper is arXiv:2609.10915, submitted September 10, 2026.
One pass, still multimodal
Naive single-step regression averages valid actions into a mushy mean. cIMLE draws m=2 candidate chunks per example, assigns each ground-truth action to its nearest candidate, and trains only that winner. The leftover candidate is free to cover another mode.
The VLM embedding is computed once. Only the winning sample gets gradients. The authors initialize the generator from a π0.5 checkpoint and fine-tune the action head only.
System-level tricks on π0.5 (PyTorch compile, Triton) top out around 20–25 Hz. The 10-step loop is still there. IMLE-VLA is the same backbone without that loop.
LIBERO and a moving plate
On LIBERO (40 tasks, 50 episodes each), IMLE-VLA at horizon H=10 averages 98.0% success, the highest among the paper’s baselines, while also leading in frequency. At H=30, success is 97.1% and action throughput is 11× π0.5 at H=10.
On LIBERO-plus perturbations (background, init, language, layout, five severities), it tracks π0.5. OpenVLA-OFT’s L1 head drops as severity rises.
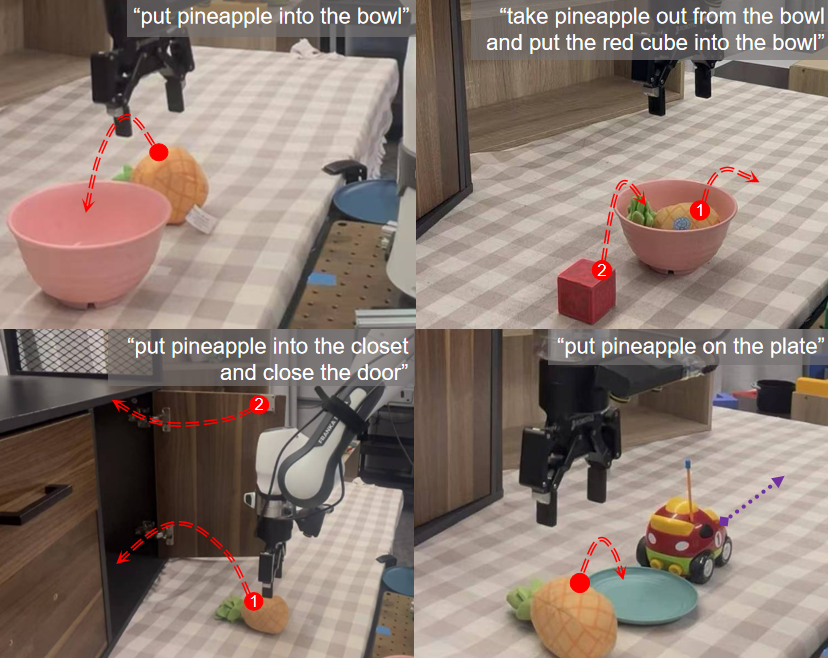
Real robot: Franka Emika Panda, NVIDIA A6000, wrist plus scene cameras, 20 episodes per task, zero-shot from DROID. π0.5 runs at 15 Hz, H=8. IMLE-VLA runs at 55 Hz, H=12.
| Task | IMLE-VLA | π0.5 | Jerk (smoother) |
|---|---|---|---|
| Pineapple in bowl | 19/20 | 15/20 | 2.7× |
| Swap pineapple and cube | 18/20 | 15/20 | 2.2× |
| Pineapple in cabinet | 15/20 | 12/20 | 3.0× |
| Pineapple on moving plate | 16/20 | 12/20 | 2.7× |
VLA-only wall-clock per successful episode drops 3.9×–6.6×. On the remote-controlled plate, 15 Hz reaches where the plate was. 55 Hz still sees it.
Code and videos are on the project page. The paper does not claim a new VLM. It claims the action head was the bottleneck.
A Human’s Take
Stop-and-go arms make me twitch. If you can keep π0.5’s success and cut the wait, that is a product change, not a benchmark trick. The moving plate is the receipt. I want this head on a humanoid next, where a 200 ms stall is a fall.