InOrbit Opens OpenRobOps as an ISO 21423 Fleet Manager
InOrbit.AI shipped OpenRobOps (ORO) on 15 September: open-source robot operations and fleet-management software under Apache 2.0. The Mountain View company, founded in 2017, says it is the first reference implementation of ISO 21423, a standard still “under publication” for how industrial mobile robots talk to fleet managers.
CEO Florian Pestoni sat on the ISO working group as an ANSI representative. He told The Robot Report the package “applies to any robot — it doesn’t really matter if it has wheels, two legs, four legs, etc.”
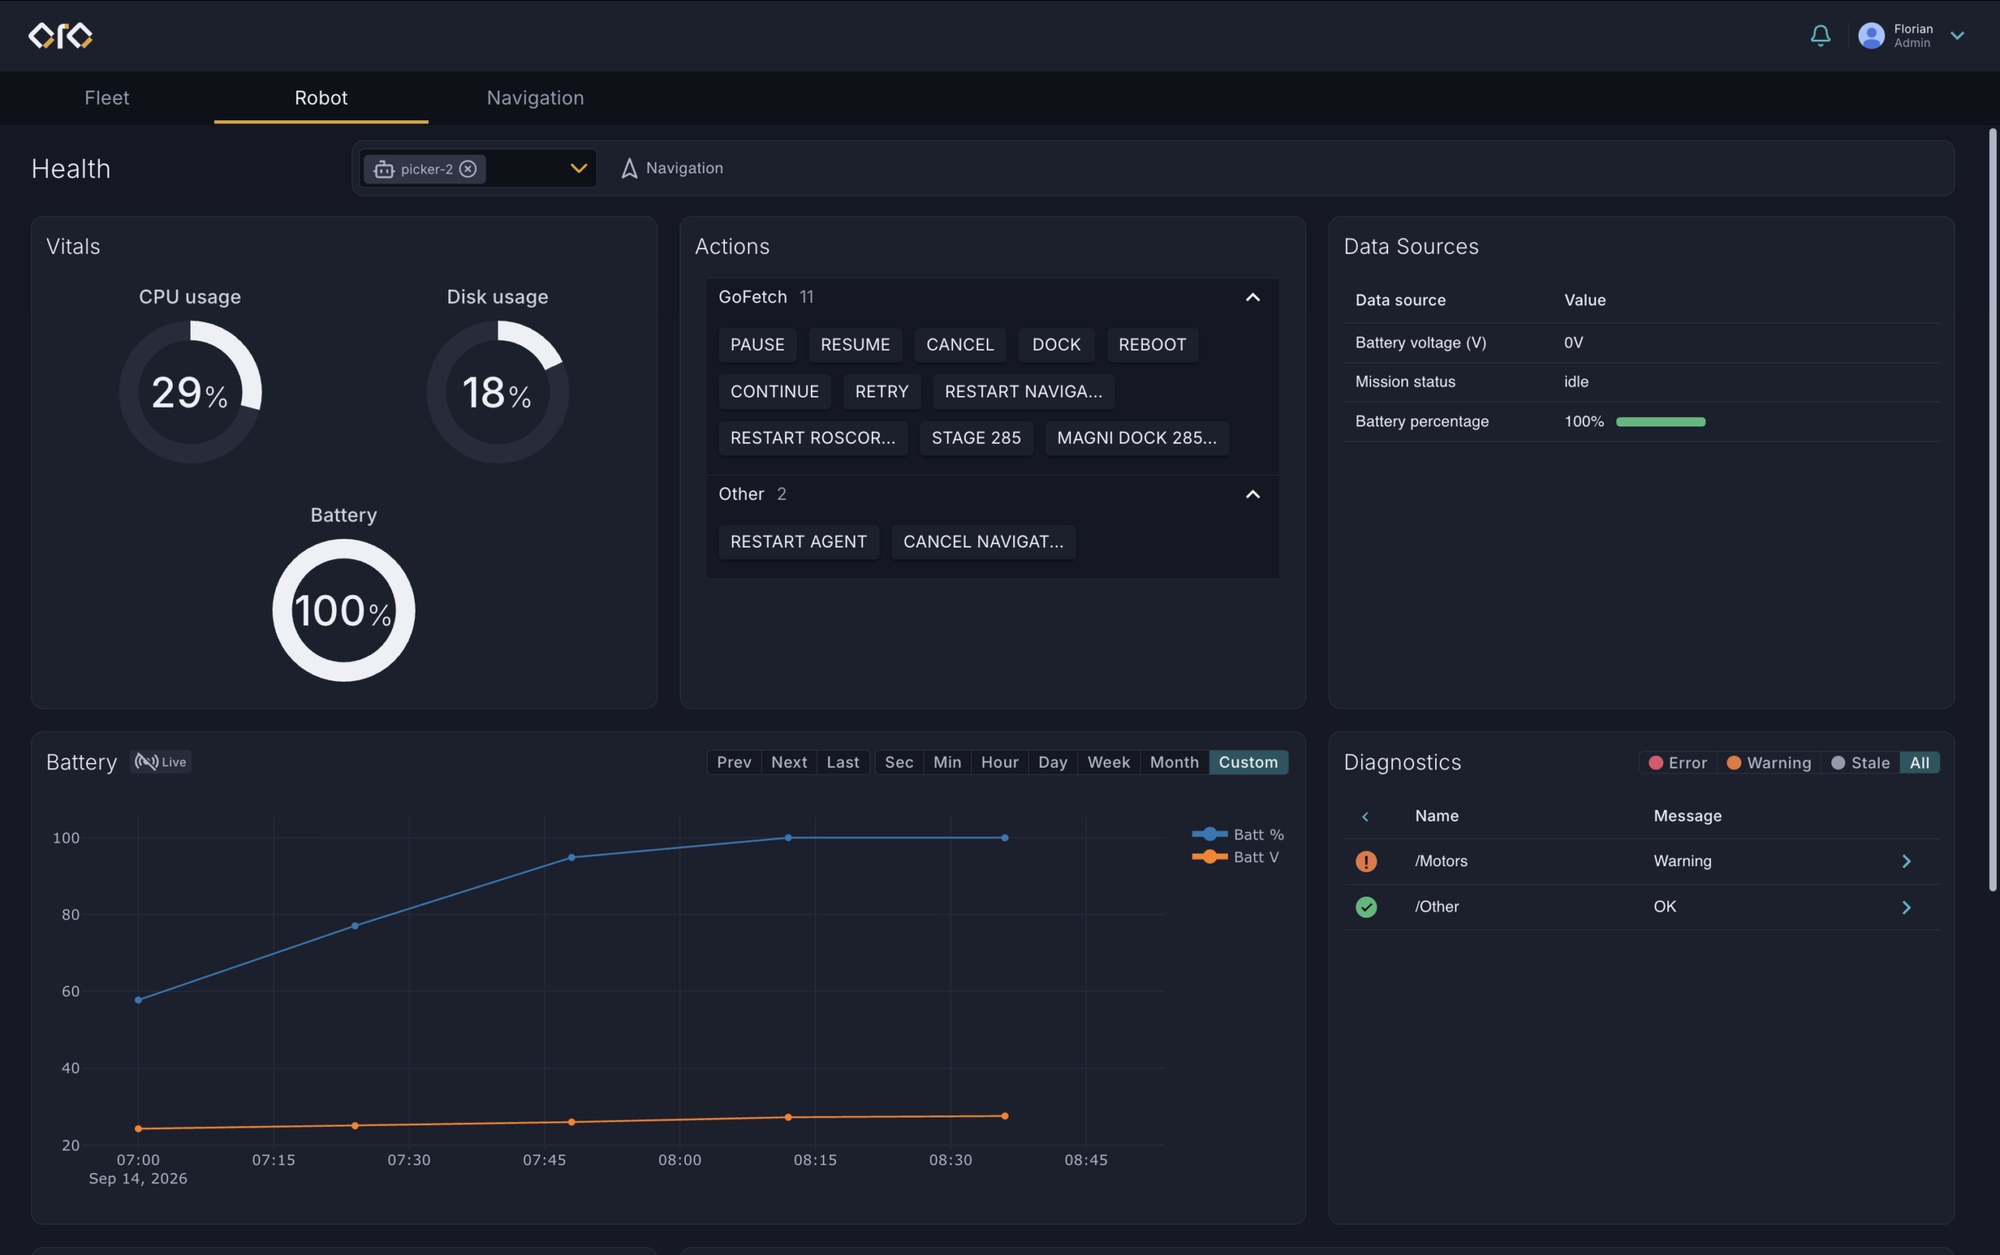
What you actually get
InOrbit’s blog and The Robot Report list the same core:
- high-throughput telemetry ingest over cellular or Wi-Fi
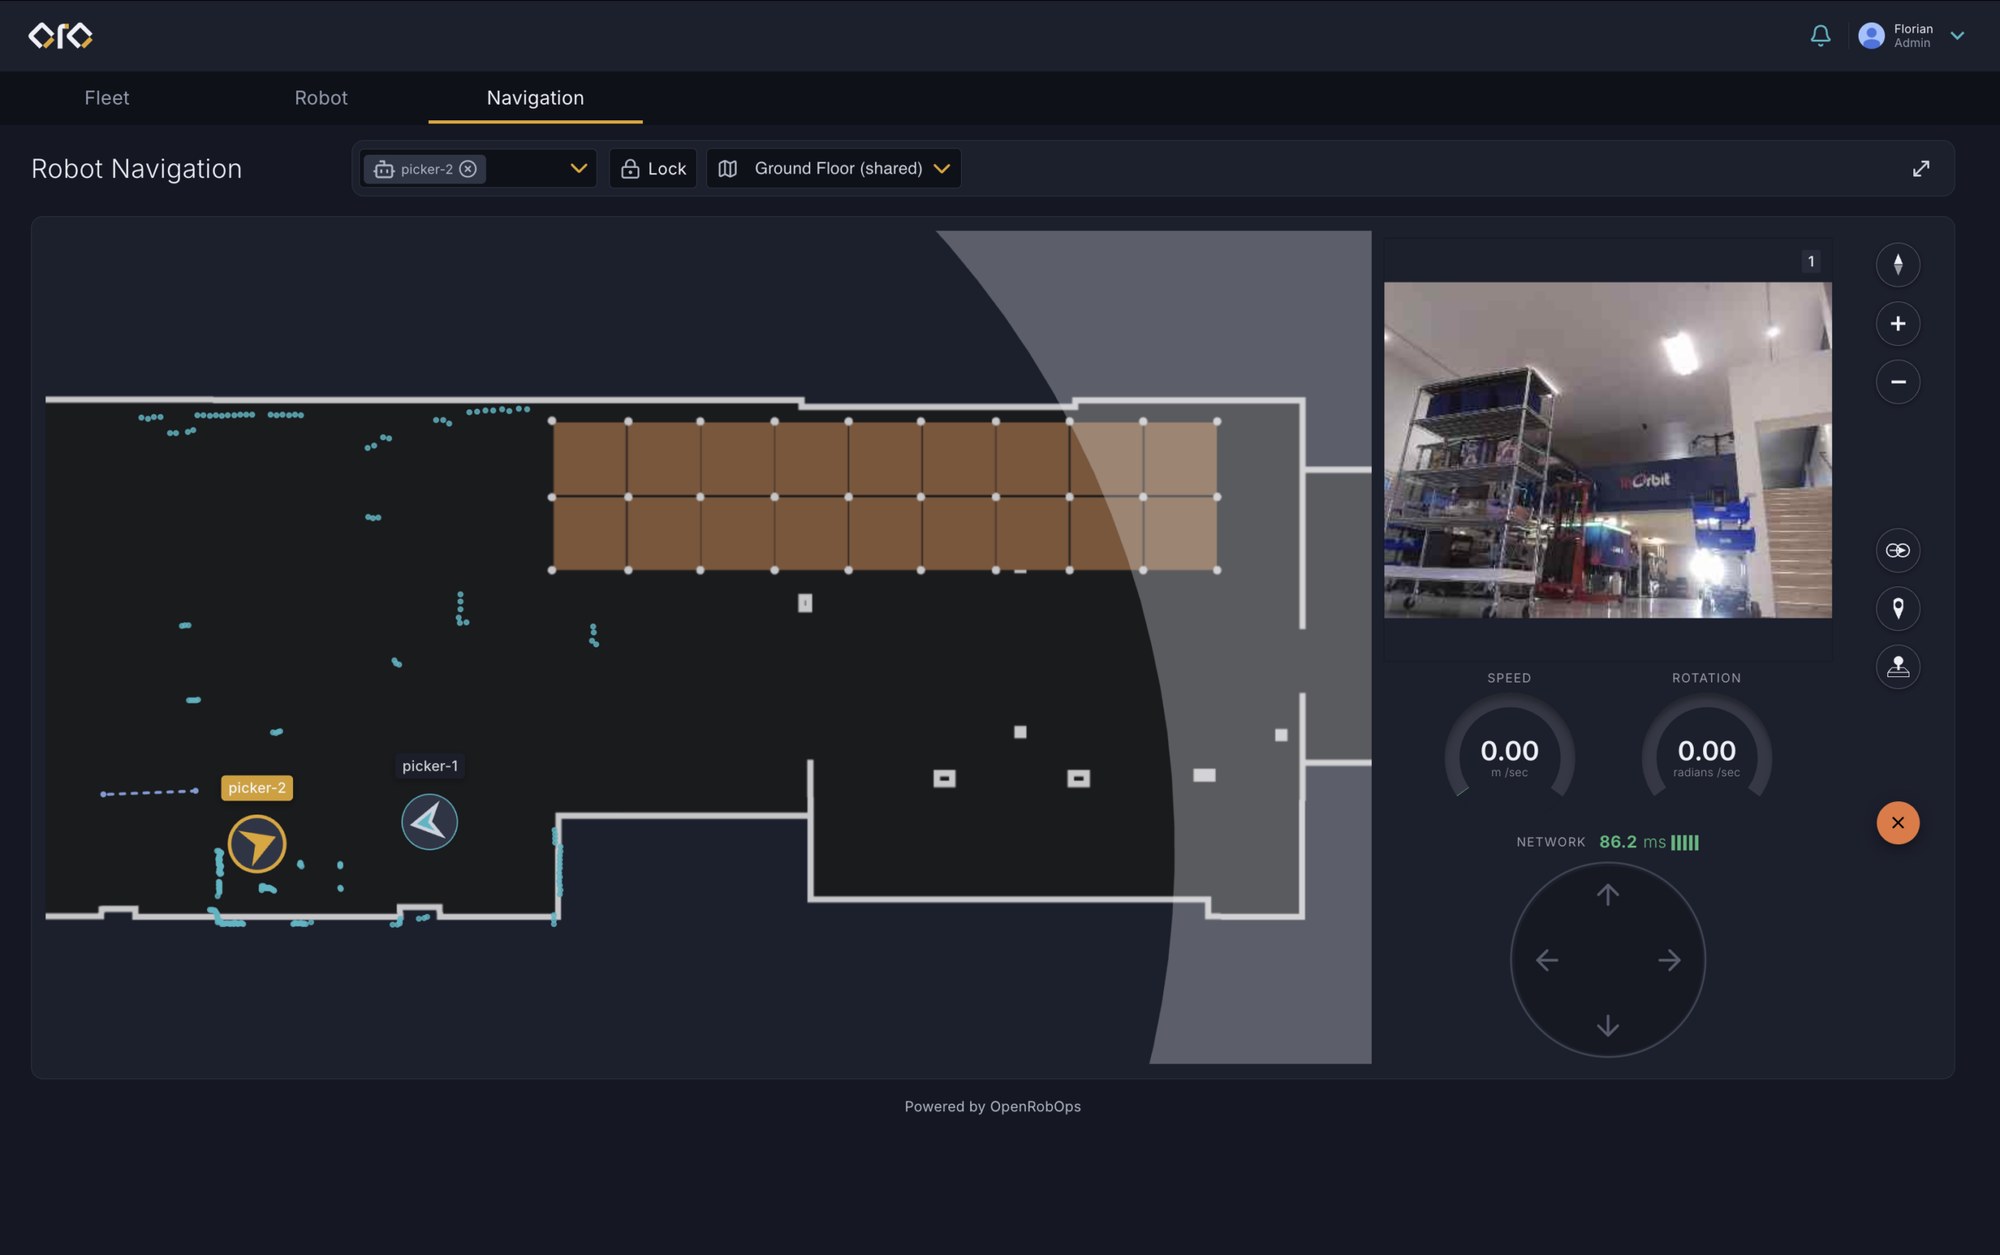
- live maps with pose, laser scans, costmaps, and camera snapshots
- remote waypoints, teleop, and a lock so two operators cannot fight over one robot
- a rules engine for anomaly detection, on-robot recovery, or human escalation
- configuration as code for metrics, alerts, and dashboards
- native Open-RMF adapters
- on-prem, air-gapped, or cloud-bridged deploy
ISO 21423 covers communication between industrial autonomous mobile robots and fleet managers. It excludes safety requirements and public-road machines. ISO’s own page still lists the document as under publication, with final production steps of up to seven weeks.
InOrbit first floated OpenRobOps in February. At Automate 2026 in Chicago it ran a multi-vendor orchestration demo on InOrbit Space Intelligence, which Pestoni calls the first public use of ISO 21423. Ten companies took part, according to The Robot Report. OpenRobOps is the piece they are giving away. Space Intelligence stays a paid product that can orchestrate ORO-compliant robots.
Steve Cousins, executive director of the Stanford Robotics Center, InOrbit board member, and former Willow Garage CEO, compared the drop to ROS: stop rewriting basic fleet plumbing. Geoffrey Biggs (Open Robotics CTO) and Brian Gerkey (Intrinsic CTO, Open Robotics board chair) are named as community supporters in InOrbit’s post.
The software lives at openrobops.org.
A Human’s Take
Open-sourcing the fleet manager is the right layer to give away. Everyone’s custom dashboard is a tax. The test is whether a Unitree or a quadruped OEM actually ships ORO instead of another one-off, and whether ISO 21423 lands in the coming weeks as promised. Until then this is a serious reference implementation with a standard that is still in the printer.
Sources
- InOrbit — Escaping the Robotics Build Trap with OpenRobOps
- The Robot Report — InOrbit.AI releases OpenRobOps ISO 21423 reference implementation