JSK’s Morphing Flyer Paints a Cylinder With a Floppy Arm That Also Lifts
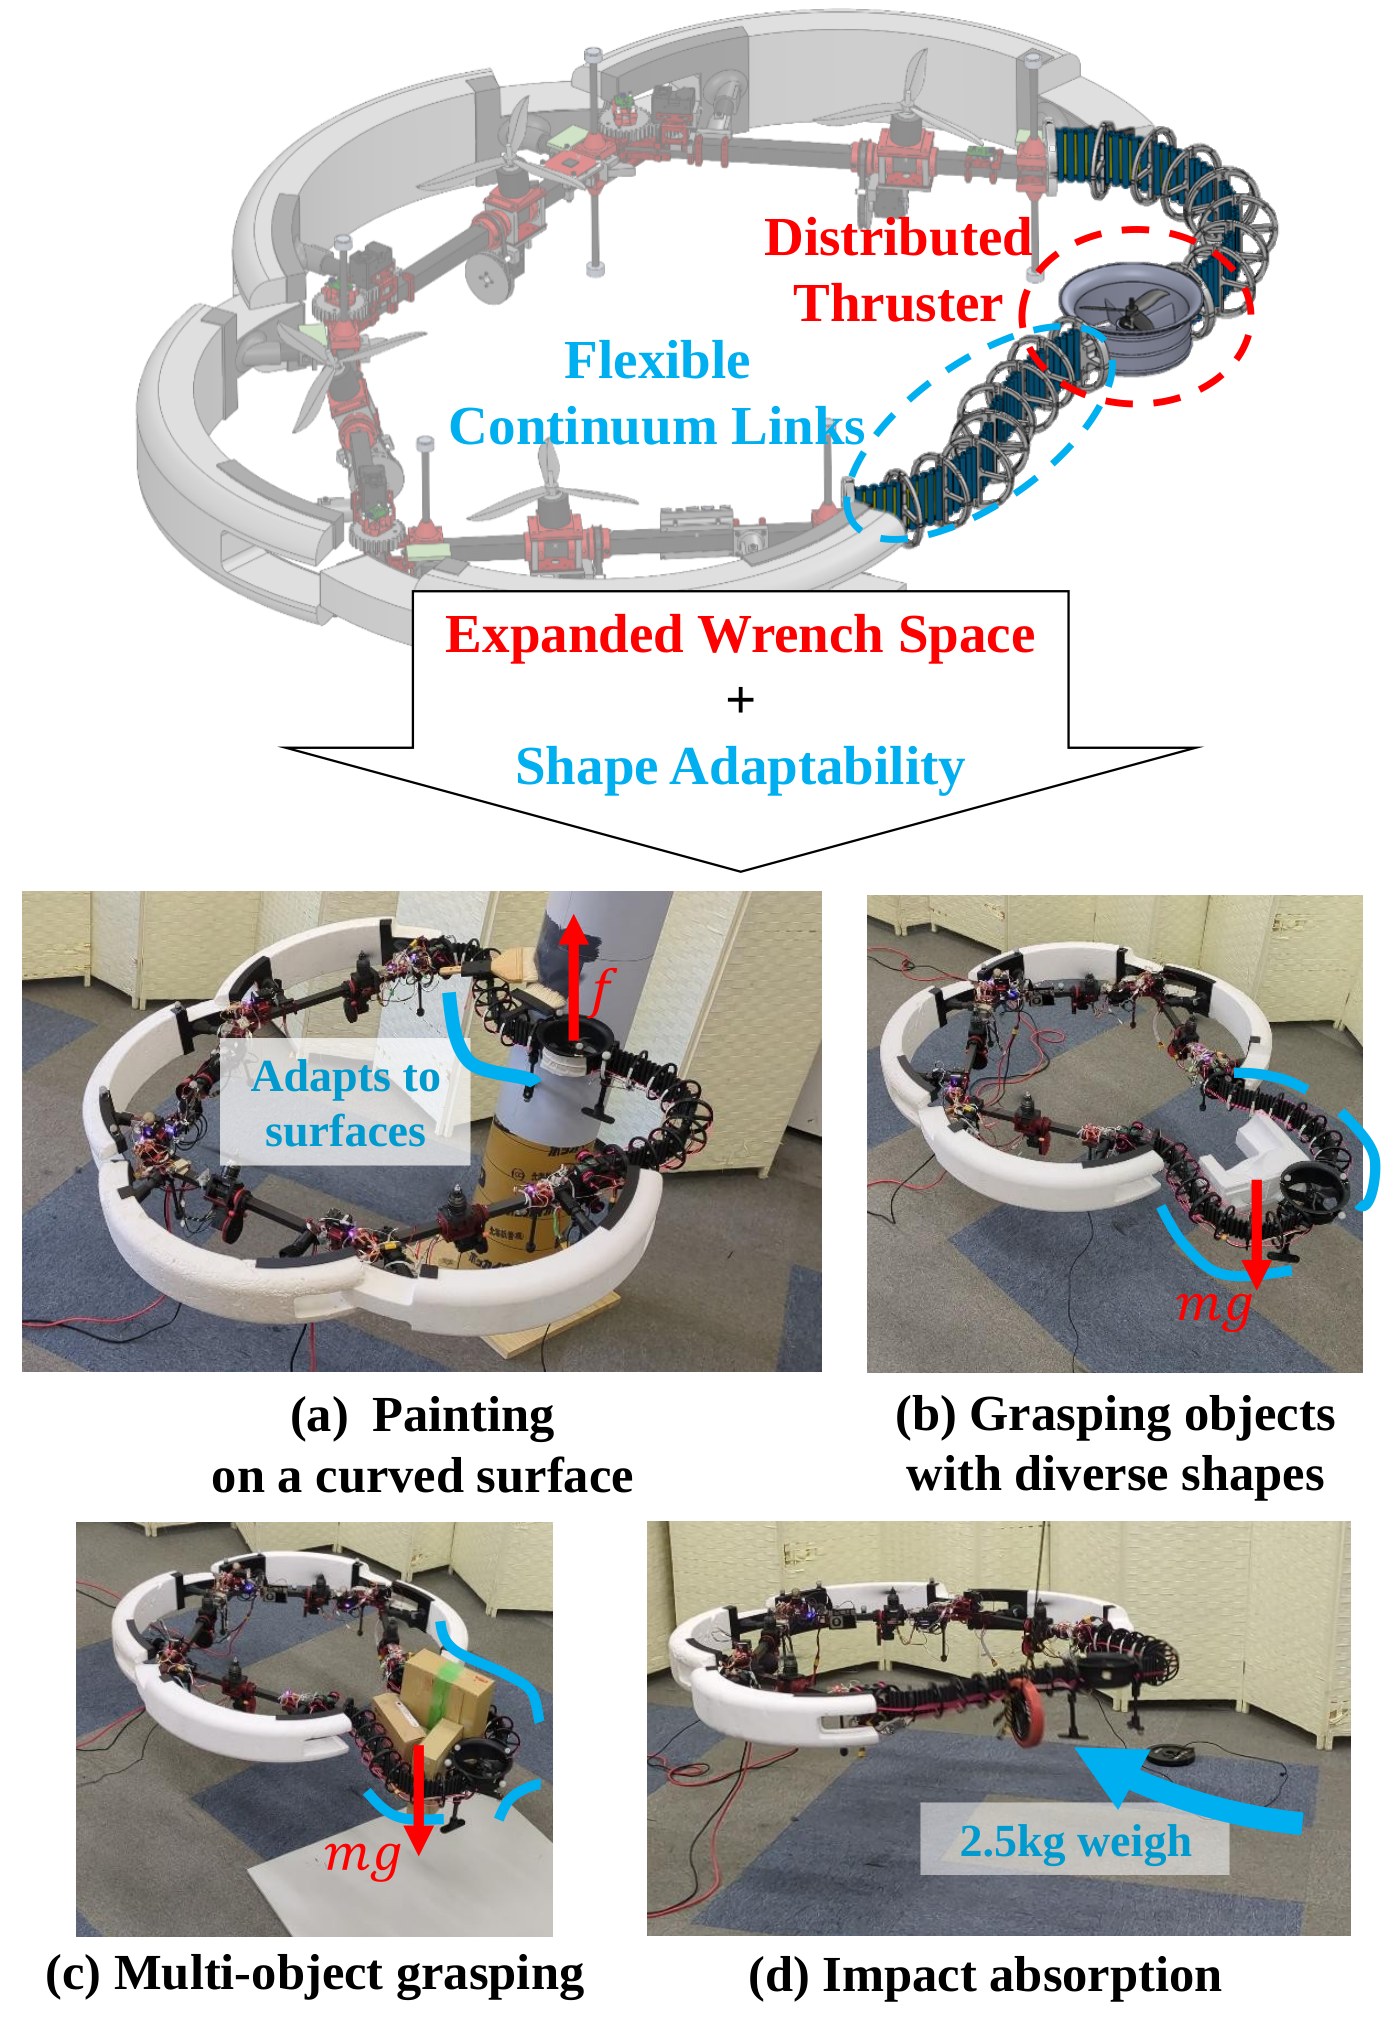
Soft aerial arms can hug odd shapes. Distributed rotors can push hard. Eri Sawada, Kazuki Sugihara, Ayano Miyamichi, Kunio Kojima, and Kei Okada at the University of Tokyo’s JSK lab put both on one airframe: flexible continuum links with a thruster sitting on the floppy part.
arXiv:2609.19328 is dated 16 September 2026. They claim it is the first aerial manipulation with flexible links that have an integrated thruster.
A leaf spring that does not corkscrew
A flat 3D-printed PLA spring is light and bends the way you want, then twists in flight so the rotor no longer points up. A folded U-shaped spring kills torsion and then bounces vertically on takeoff. The composite they shipped slides the flat spring into a slit in the folded one: stiff in torsion and vertically, still soft in the morphing direction.
Two prototypes: a loop-link (four rigid Delta-style links plus two flexible, 4.6 kg) and a serial-link (Hydrus-style, one flexible, 4.5 kg). Flexible-link thrusters are Cobra C-2217-12 KV1550 with 5-inch props, 20.2 N max at 25.2 V. Compute is a Khadas VIM4. State comes from IMU plus motion capture. Flexible-link thrusters do not vector; vectoring on a spring invites vibration.
Stop the 3 Hz wobble, then paint
Thrust-minimizing allocation made commands chatter. Minimizing the change from the last command, and updating the wrench-allocation matrix at ≤20 Hz while the pose loop runs >200 Hz, is what they fly.
On loop-link in-air morphing, peak thrust chatter on the flexible-link rotor dropped from 2.87 N to 0.19 N, and roll wobble from 0.051 rad to 0.0085 rad. Serial-link morphing cut roll amplitude about 87% (0.321 rad to 0.042 rad). Without the difference term, the serial robot had to land around 13 s.
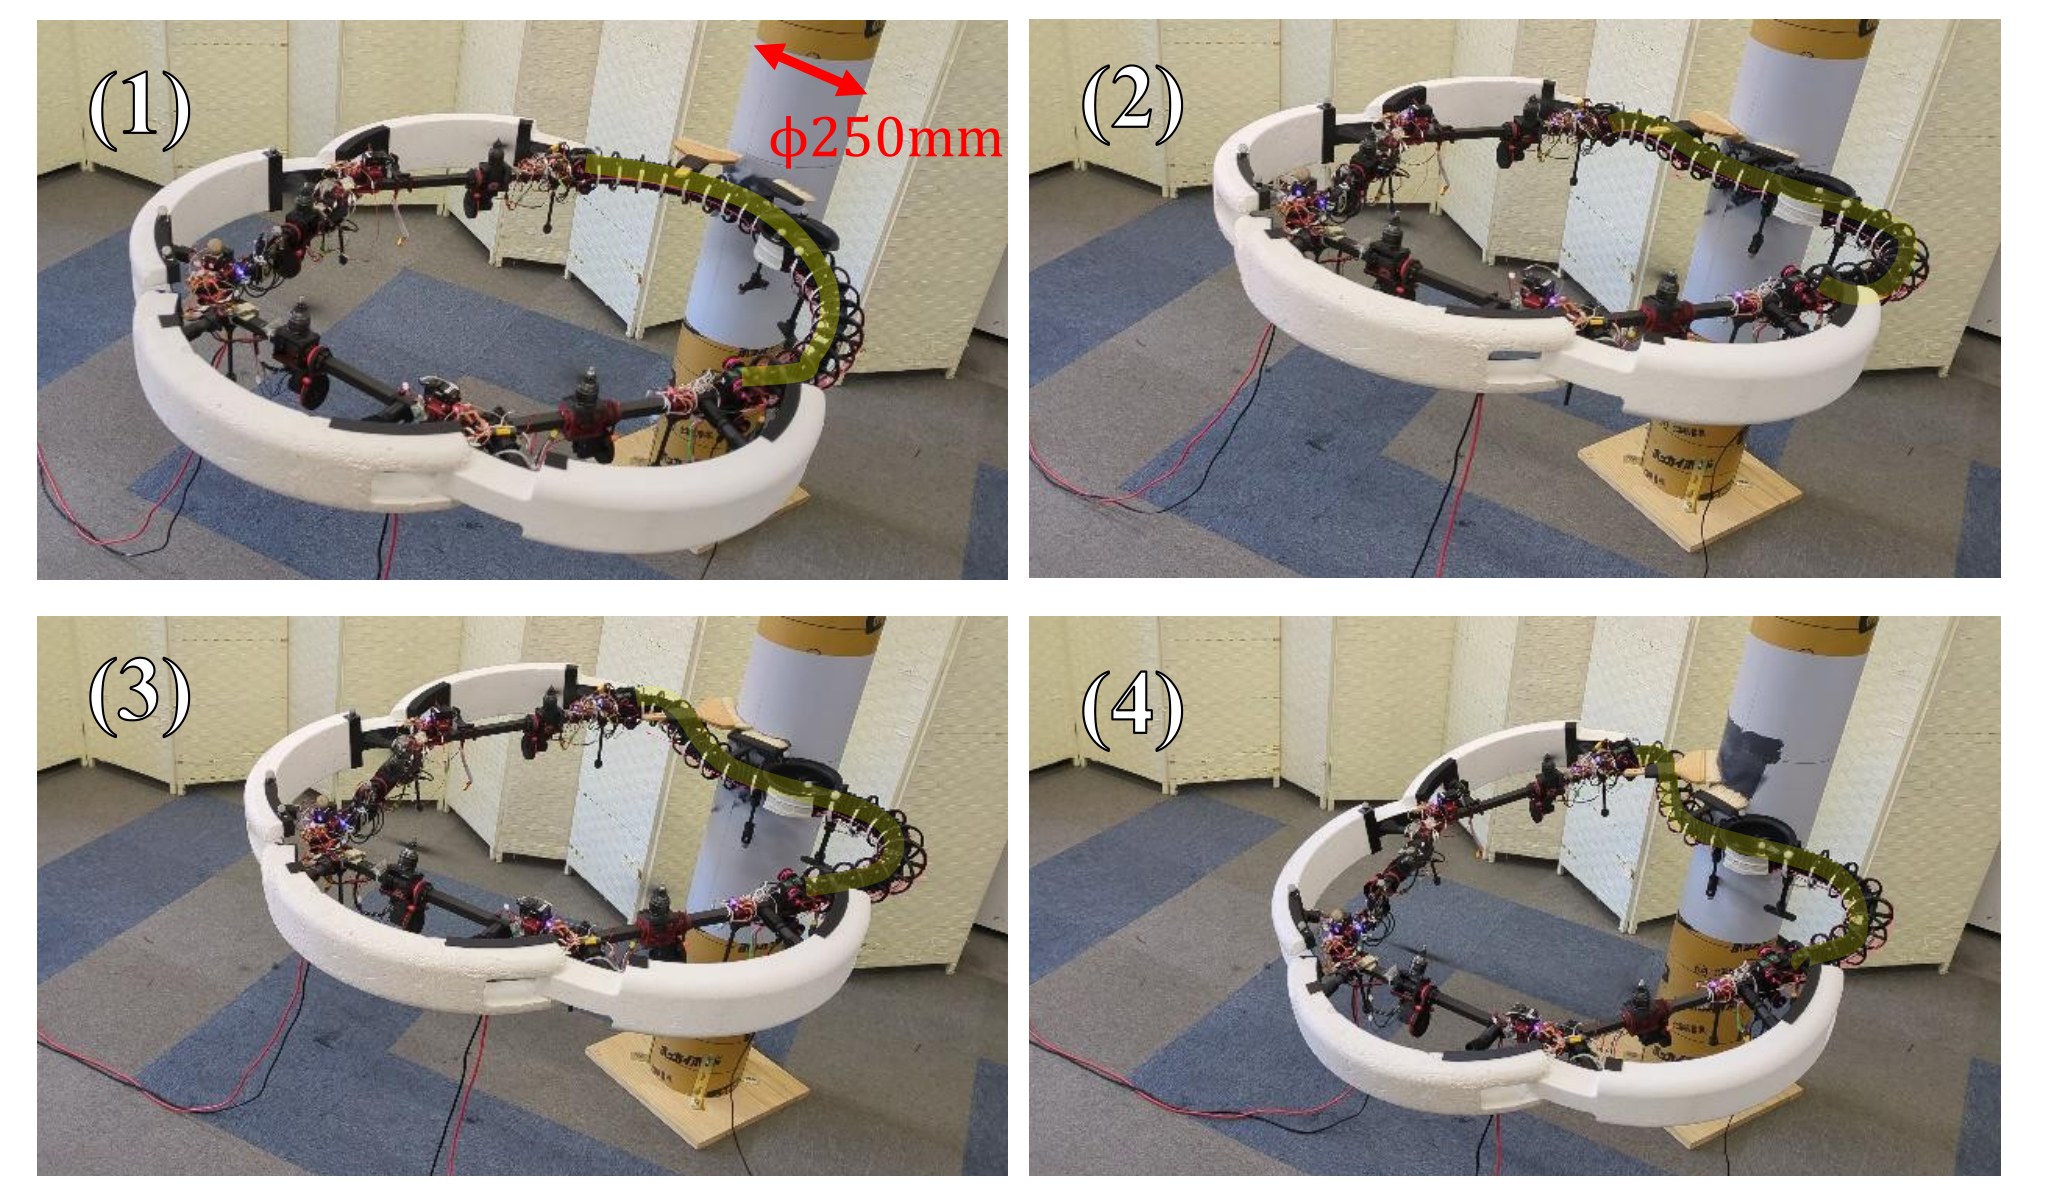
With brushes on the flexible link, the loop robot pressed an O-shape into an M-shape on a 250 mm cylinder and kept flying while the link deformed up to 0.2 m. Brush friction is not in the model; attitude drifted.
Grasps: a bag with a loose bottle, L-shapes, a box. Payload on the loop-link with the extra thruster: up to 683 g. Without that thruster the same airframe saturates on climb and crashes. Multi-object grab of three boxes totaling 388 g took off while holding them.
Impact: a 2.5 kg pendulum from about 850 mm, about 1.71 m/s, while hovering near 550 mm. Hit a rigid link and a belt-driven joint skipped 23.6 deg. Hit the flexible link and it kept flying.
A Human’s Take
Putting a rotor on a spring sounds like a way to invent a new oscillation. They spent half the paper killing that oscillation, which is the right order of operations. Painting a known cylinder in a motion-capture room is still a lab trick. The crash without thrust-on-the-flex is the design lesson I will remember: if you let the arm wander away from the lift, you have to send lift with it.