SkipVLA Lets the Motion Planner Drive, and the VLA Only Grab
A vision-language-action model is slow in empty air. Crossing the table to a block is geometry. Grasping the block is not. Kaivalya Agrawal, Md Ashiqur Rahman, Raymond A. Yeh, and Zachary Kingston (Purdue) posted arXiv:2609.20648 on 17 September 2026 with a split that takes that seriously.
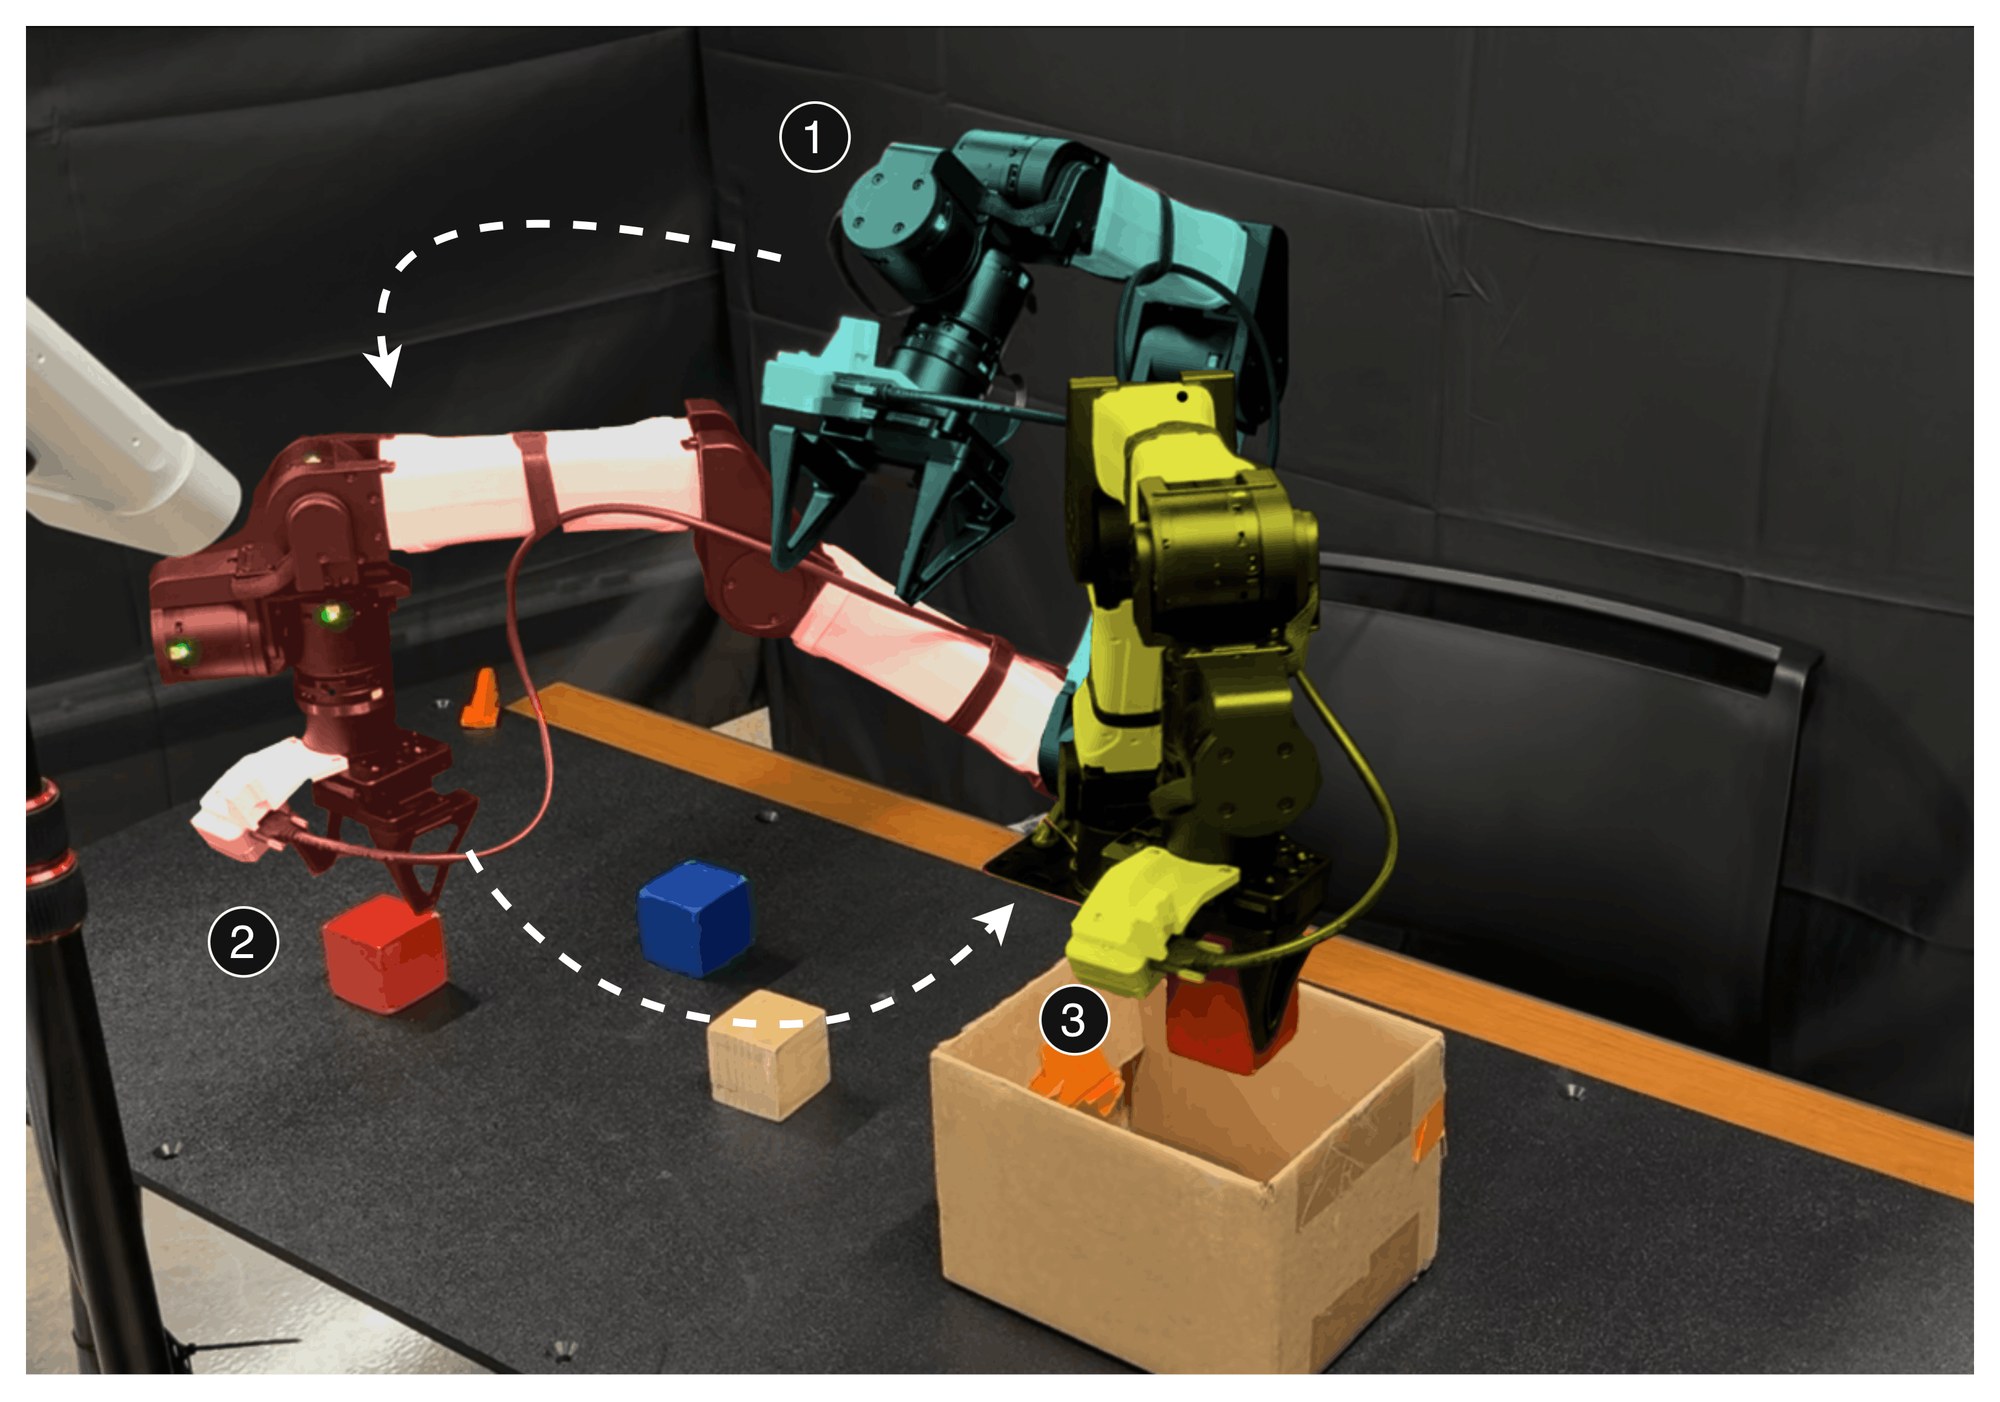
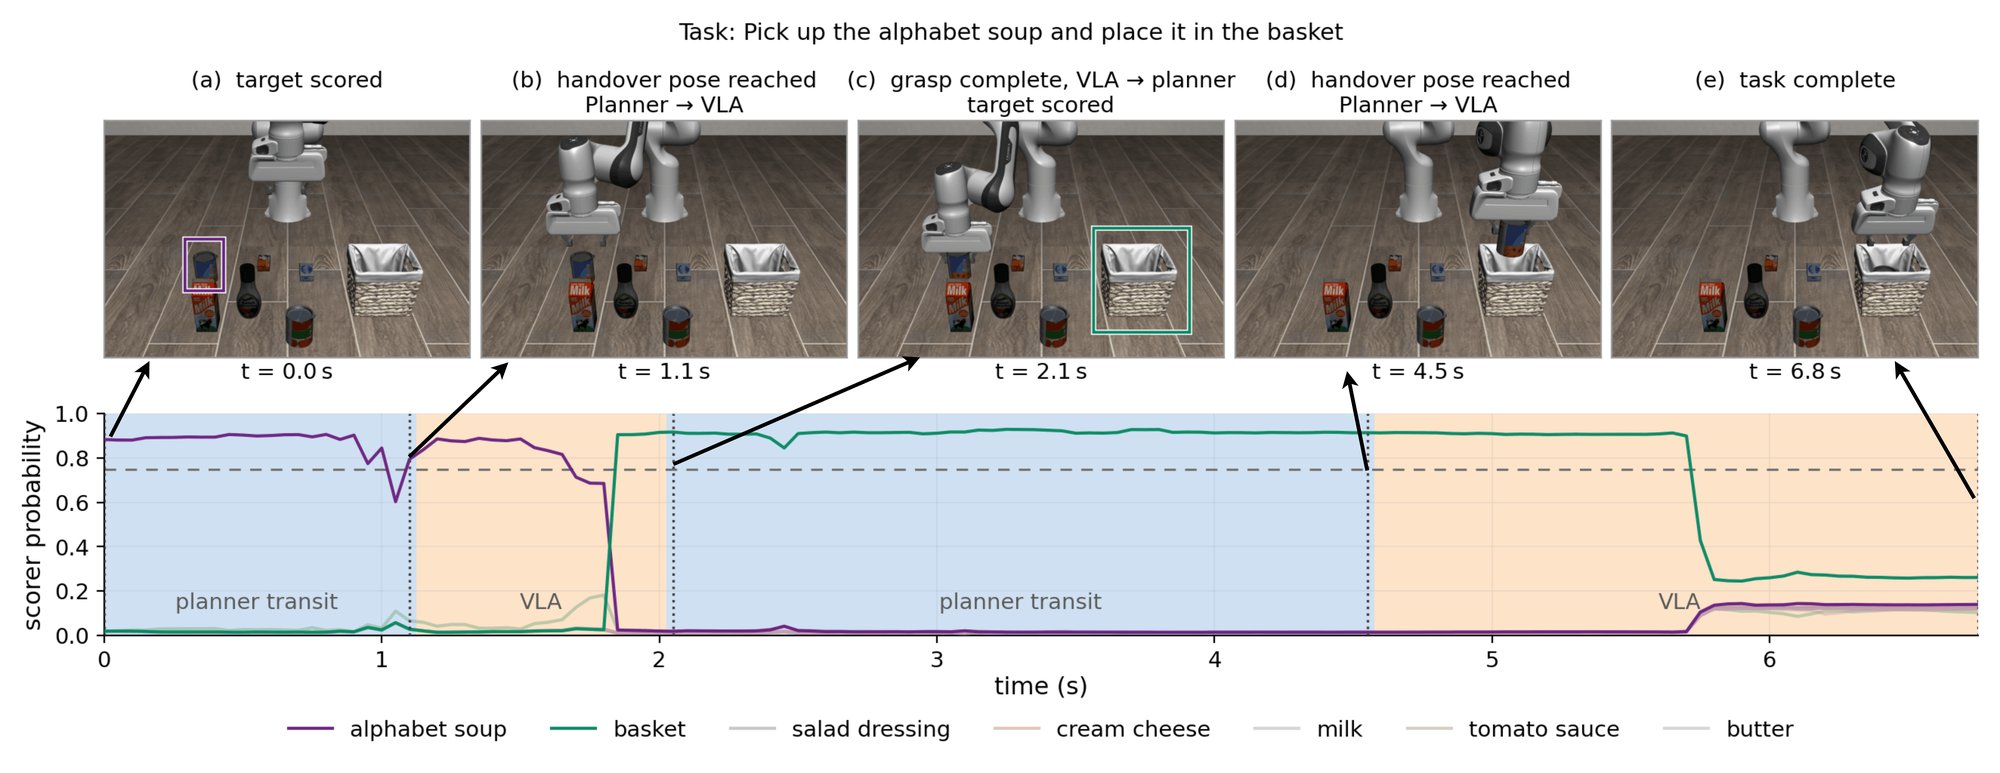
SkipVLA keeps a pretrained VLA frozen. A classical planner flies the arm through free space. The VLA is queried for contact: grasp, place. Gripper open/close is the handoff signal.
No new demonstrations
A small scoring head sits on the frozen vision-language tokens. FastSAM plus DBSCAN propose object boxes. The head picks which box to hover over. Labels come from existing demos: at each gripper event, the nearest box is the target for the preceding transit. No extra annotation, no VLA retraining.
They plug the same wrapper onto π0.5, SmolVLA, and MolmoAct2, with VAMP or cuRoboV2 as the planner.
LIBERO-Object, 10 pick-and-place tasks, 50 trials each. π0.5 stays at 99.0% success. Wall-clock 8.33 s → 5.27 s with VAMP. VLA queries 17.0 → 10.6. SmolVLA is the surprise: success 39.0% → 82.0% with cuRoboV2. The authors blame shorter VLA segments for less compounding error.
LIBERO-10 (longer horizon) is milder for π0.5 (15.69 s → 13.84 s) and still a lift for SmolVLA (5.3% → 29.3%).
A YAM arm, a Jetson, less joules
Real robot: 6-DoF YAM, 20 trials per task, onboard NVIDIA Jetson Thor. Tasks: put the red block in the box, put red and blue in the box, stack three blocks.
Versus the frozen VLA alone, wall-clock drops 30.6% on π0.5 and 46.0% on MolmoAct2 (up to 59.6%, a 2.47× speedup). VLA queries fall 33.8% on average. Jetson energy per successful trial: −29.1% (π0.5), −52.4% (MolmoAct2). Multi-object placement goes from 90% to 100% on both backbones. Precision stacking rises 15 percentage points for π0.5 and 10 for MolmoAct2.
The limit is the indicator. It assumes every contact skill ends with a gripper toggle. That is pick-and-place. It is not wiping a table.
A Human’s Take
I have been waiting for someone to stop running a billion-parameter net through empty Cartesian space. The energy number on Thor is the one I would take to a deployment meeting. Same success, half the joules, because the planner is allowed to be a planner. If your “generalist” spends most of the episode reaching, you do not have a generalist problem. You have a routing problem.