TacPAC Corrects a Grasp Mid-Chunk Using Predicted Touch
Most world-action models guess the future, then freeze the plan until the next chunk. TacPAC (arXiv:2609.05266, 4 September 2026) keeps that plan and lets new fingertip images rewrite the part that has not executed yet.
The authors — Zipei Ma, Xiaofei Wei, Junzhe Jiang, Shunlin Lu, and Li Zhang — put the code on GitHub under Logos Robotics Group. The robot in the paper is a Flexiv Rizon 4.
Predict, cache, patch
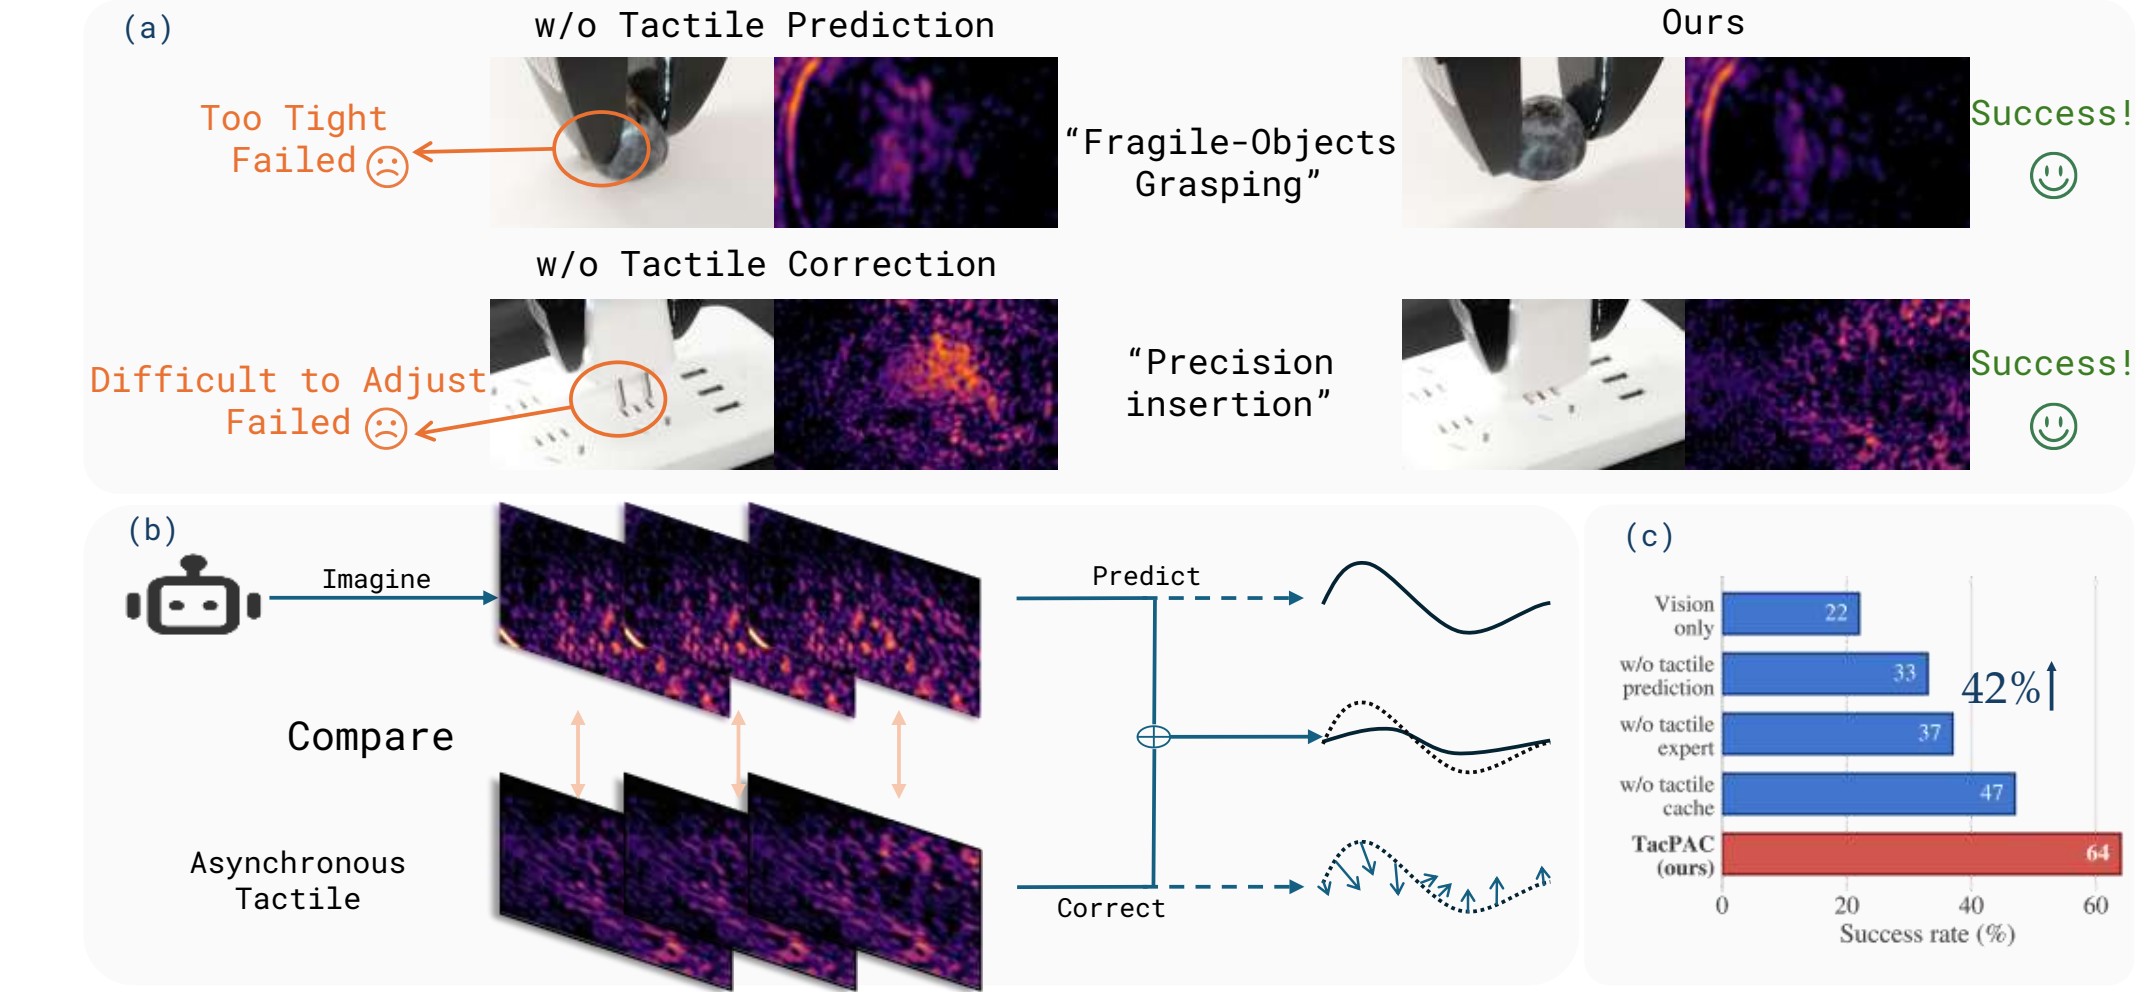
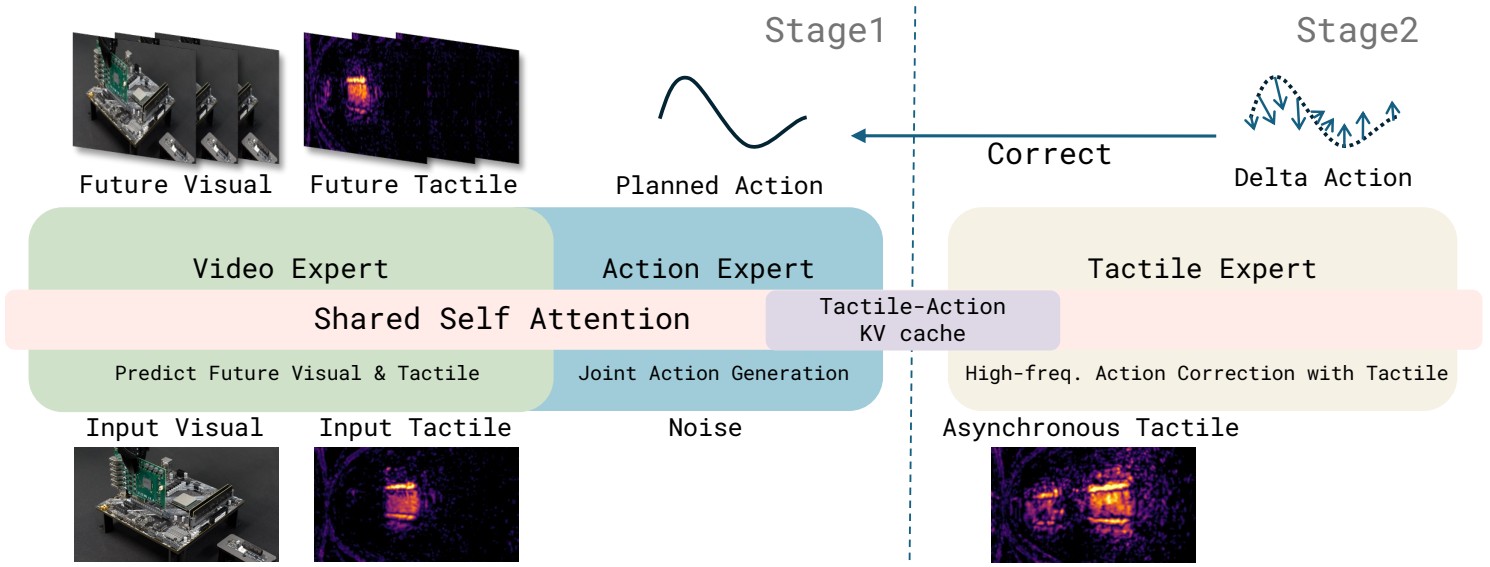
Stage 1 trains a tactile-predictive world-action model: a video expert forecasts future RGB and tactile frames while an action expert denoises a chunk. Stage 2 freezes that base. For each planned chunk, TacPAC caches the predicted contact and the action representation tied to it. A tactile expert then reads each new tactile image against that cache and outputs a delta on the unexecuted suffix.
The README’s timing: one correction is 30.4 ms (32.9 Hz) in their setup, 20.7× faster than regenerating the whole chunk. The paper’s line is the same idea — feedback is interpreted against what the plan expected, not as a raw reflex.
Five contact-rich tasks
Twenty real-world trials per task. Average success:
| Variant | Plug | Fruit | Chip | Bottle | Card | Avg. |
|---|---|---|---|---|---|---|
| Vision only | 15 | 30 | 60 | 5 | 0 | 22 |
| Tactile prediction, no expert | 35 | 50 | 65 | 20 | 15 | 37 |
| Correction, no prediction | 40 | 25 | 45 | 30 | 25 | 33 |
| Both, no cache | 40 | 50 | 75 | 40 | 30 | 47 |
| TacPAC | 80 | 65 | 90 | 40 | 45 | 64 |
The tasks are charger-plug insertion, multi-object fruit transfer, potato-chip transfer, empty-bottle uprighting, and expansion-card insertion. The 16-point gap over the strongest ablated baseline is the cache: predicted contact plus the plan’s own keys, reused every tick.
Datasets and checkpoints are “being prepared.” The repo currently has model, training, preprocessing, and deployment code.
A Human’s Take
Predicting touch is cute. Using that prediction as the thing you compare the real fingertip against, while the arm is still moving, is the part I will steal. 22% to 64% on five messy tasks is a real jump. Bottle uprighting still sitting at 40% is the honest number. Ship the datasets.