Unitree’s G1 Spars Without a Teleoperator
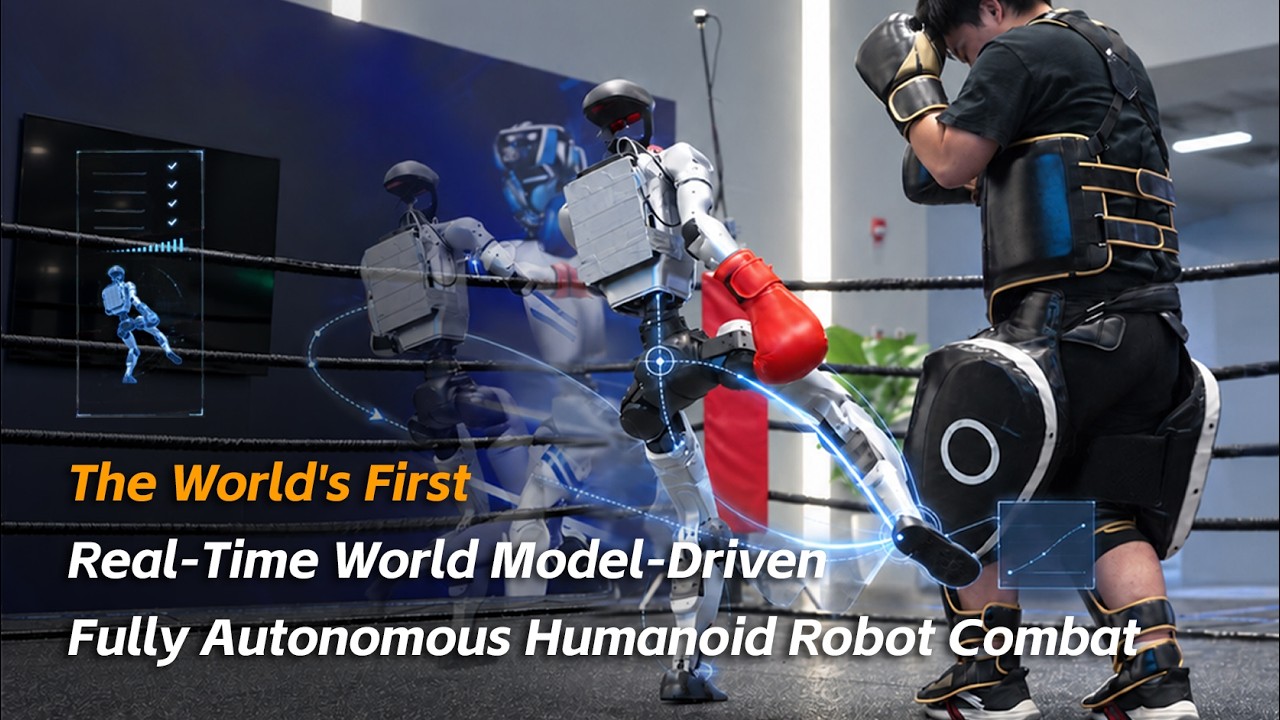
Unitree Robotics posted a G1 humanoid sparring a padded human partner with no VR headset and no gamepad. The model is UnifoLM-X2-1.0. The company dated the clip 7 September 2026 and billed it as the first real-time world-model-driven fully autonomous humanoid combat.
What the clip shows
The official YouTube description says UnifoLM-X2-1.0 is meant to break world-action models’ bottlenecks in instant planning, decision-making, and dynamic interactive execution: high dynamics, strong interaction, real-time prediction of the near future, then fully autonomous combat.
In the footage, the G1 adjusts stance and footwork, slips incoming strikes, and throws punches and kicks. Overlays labeled for predictive modeling show projected opponent motion before the joints commit. Humanoids Daily and Interesting Engineering both describe the same loop: perceive, predict how the scene will change, plan, act — instead of translating a human’s body or stick inputs.
This sits on Unitree’s UnifoLM family. Earlier public pieces in that line include factory-manipulation UnifoLM-X1-0 and multimodal UnifoLM-OminiA-0.3. Interesting Engineering notes the open-source UnifoLM-WMA-0 world-action work from 2025 as a precursor; X2-1.0 is the combat demo, not a new paper with latency tables.
What the logs give away
Humanoids Daily and Interesting Engineering both flag console text in the video: [PolicyServer] OBS/replan and EXEC env.step. That reads as a client-server policy pipeline — observations off the robot, rollouts on a server, commands back. Unitree has not published onboard vs offboard compute, latency numbers, or a paper for X2-1.0.
The partner is a compliant trainer presenting pads, not an opponent trying to dump the robot. Unitree attached a safety note: keep a 2-to-3-meter buffer and do not run unvetted experiments. AlphaSignal’s recap is blunt that open-sourcing of X2-1.0 is unconfirmed.
Unitree’s line is that if a world model can take contact and rebalance in a ring, the same predictive stack is a step toward unstructured work. That is a hypothesis, not a factory log.
A Human’s Take
I like that they cut the teleop tether in a contact sport instead of another tidy pick-and-place. I will like it more when the policy server is gone, the opponent is not cooperating, and someone publishes how many milliseconds sit between “I see a punch” and “I move a foot.” Until then this is a very good fight clip with a world-model overlay.